IBH Earth V1
An autonomous carrier for up to 1,500 kg that moves in any direction.
- Payload
- 1,500 kg
- Pallets, racks or custom modules
- Length × width (mm)
- 1716 × 1116
- Height 340 mm
- 360° safety coverage
- 4 LiDARs
- One 270° LiDAR at each corner
- Run time per charge
- 16 h
- Charges itself at the station
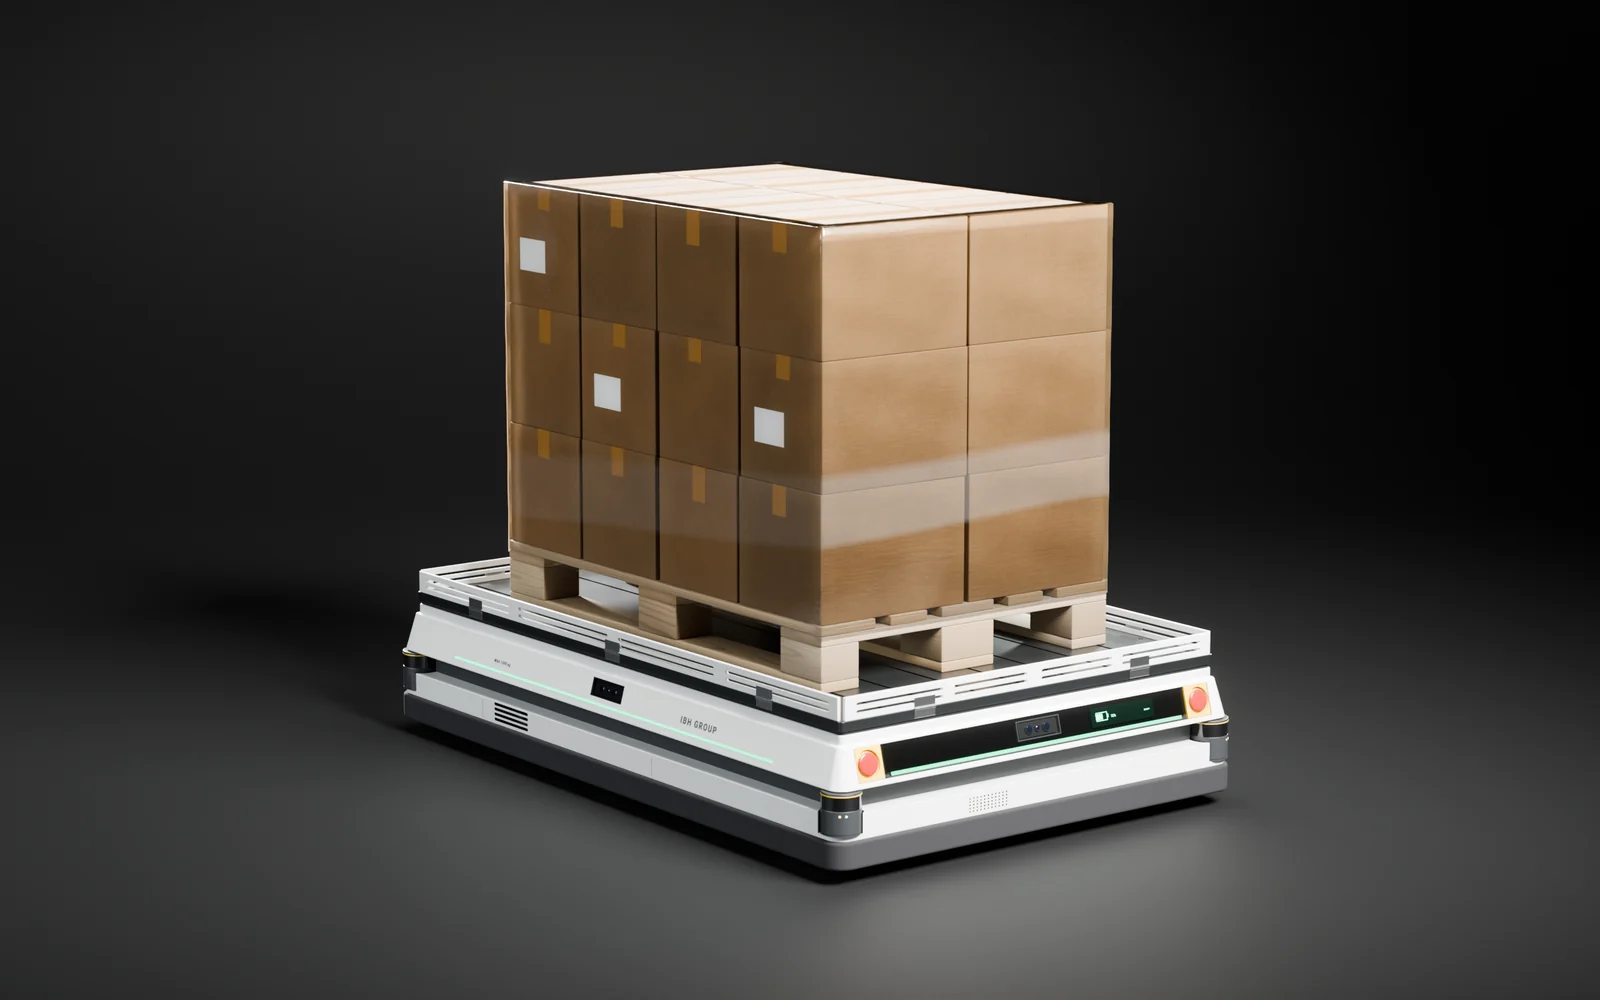
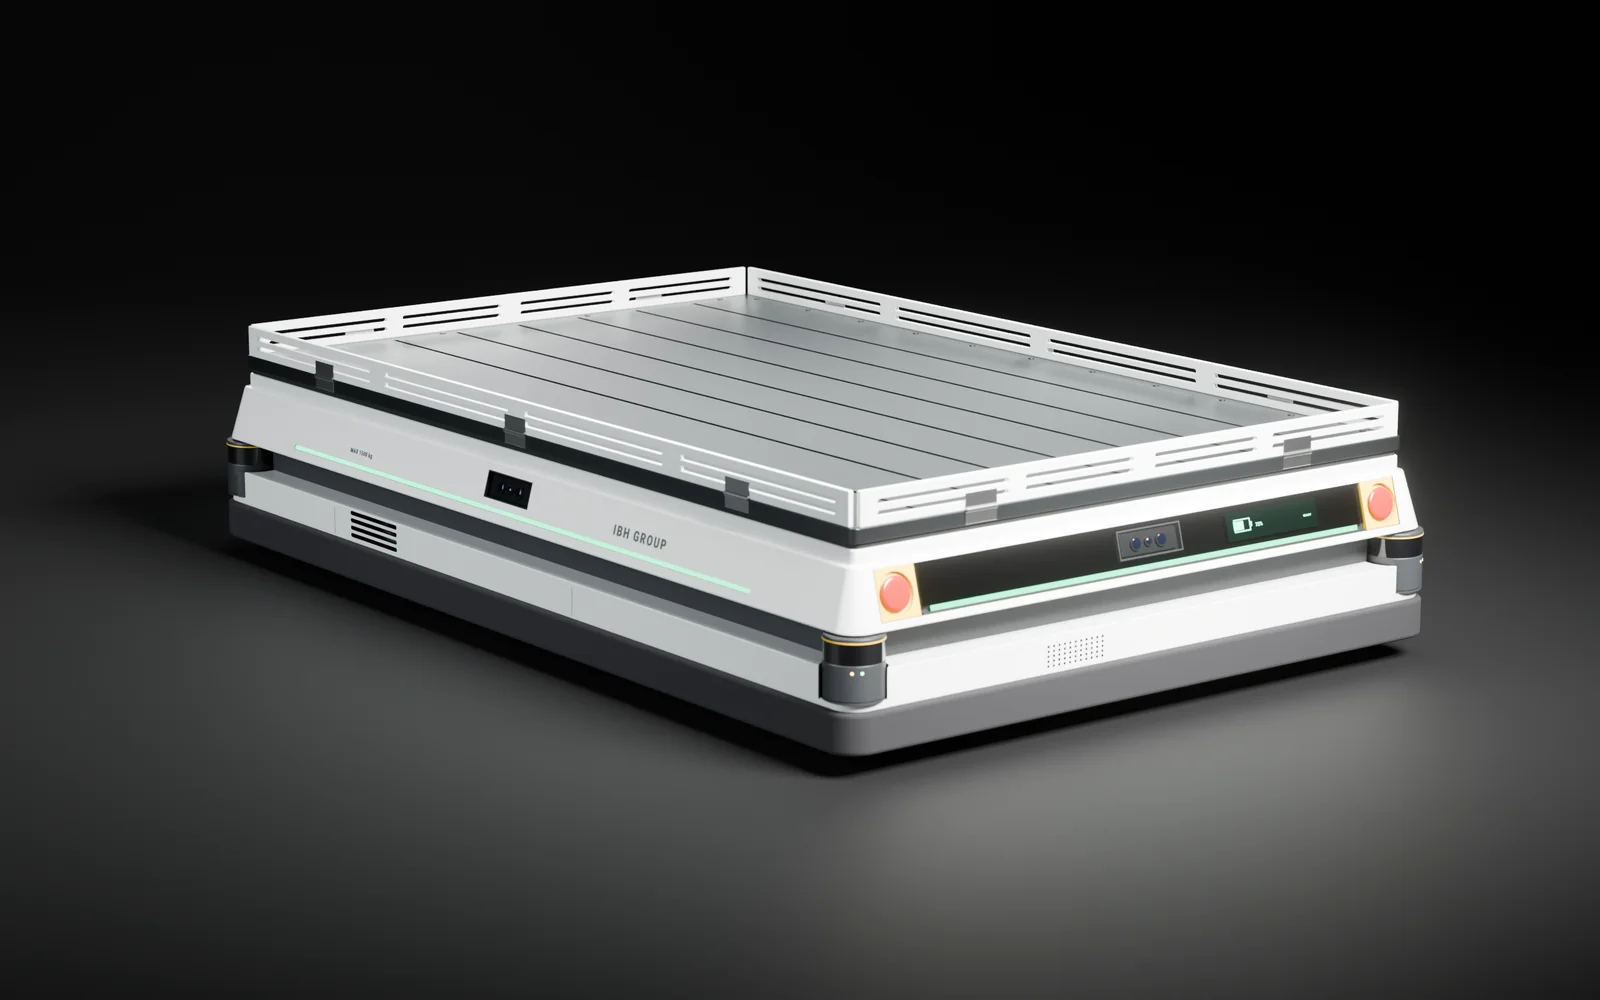
IBH Earth V1 is IBH GROUP’s heavy autonomous carrier for factories and warehouses. It moves pallets, racks and custom modules weighing up to 1,500 kg with no driver and no floor tape or rails. Its 1640 × 1040 mm aluminium deck with seven T-slots takes Euro and ISO pallets directly, and racks, roller conveyors or lifts bolt straight onto the slots.
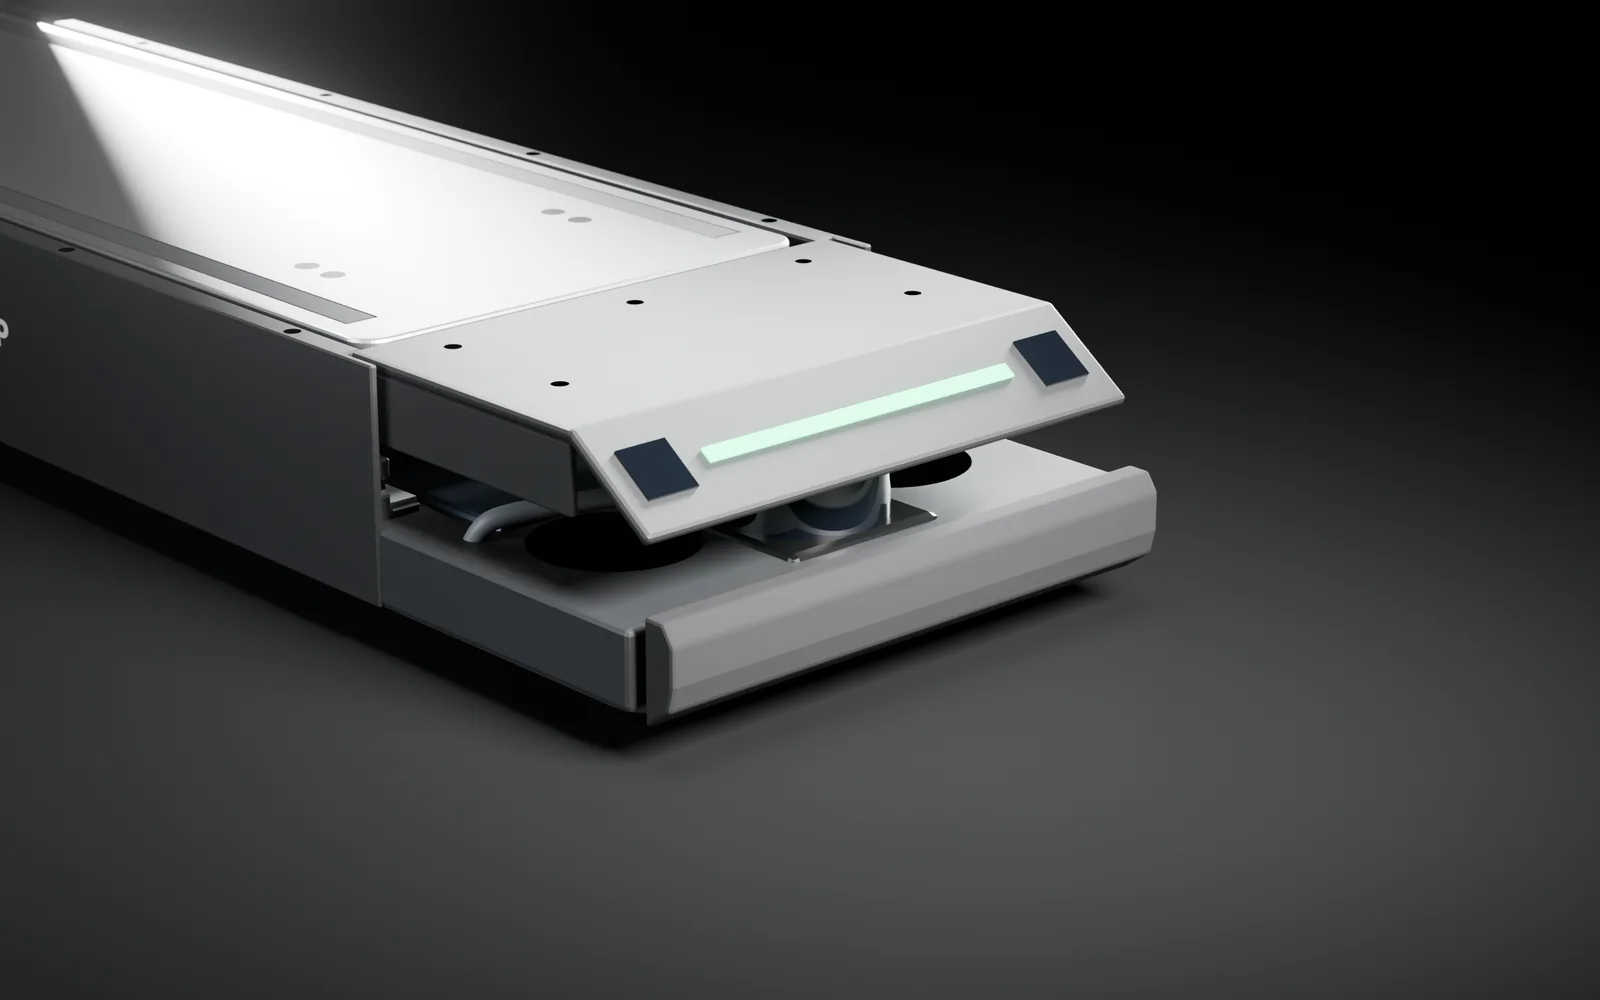
Four driven mecanum wheels move it forward, back, sideways and diagonally and turn it in place within a circle about 2 m across, so it manoeuvres through narrow aisles without turning around and docks with precision. Four safety LiDARs and four depth cameras watch all 360° around it, and the AI computer on board plans its path moment by moment, with no dependence on a server.
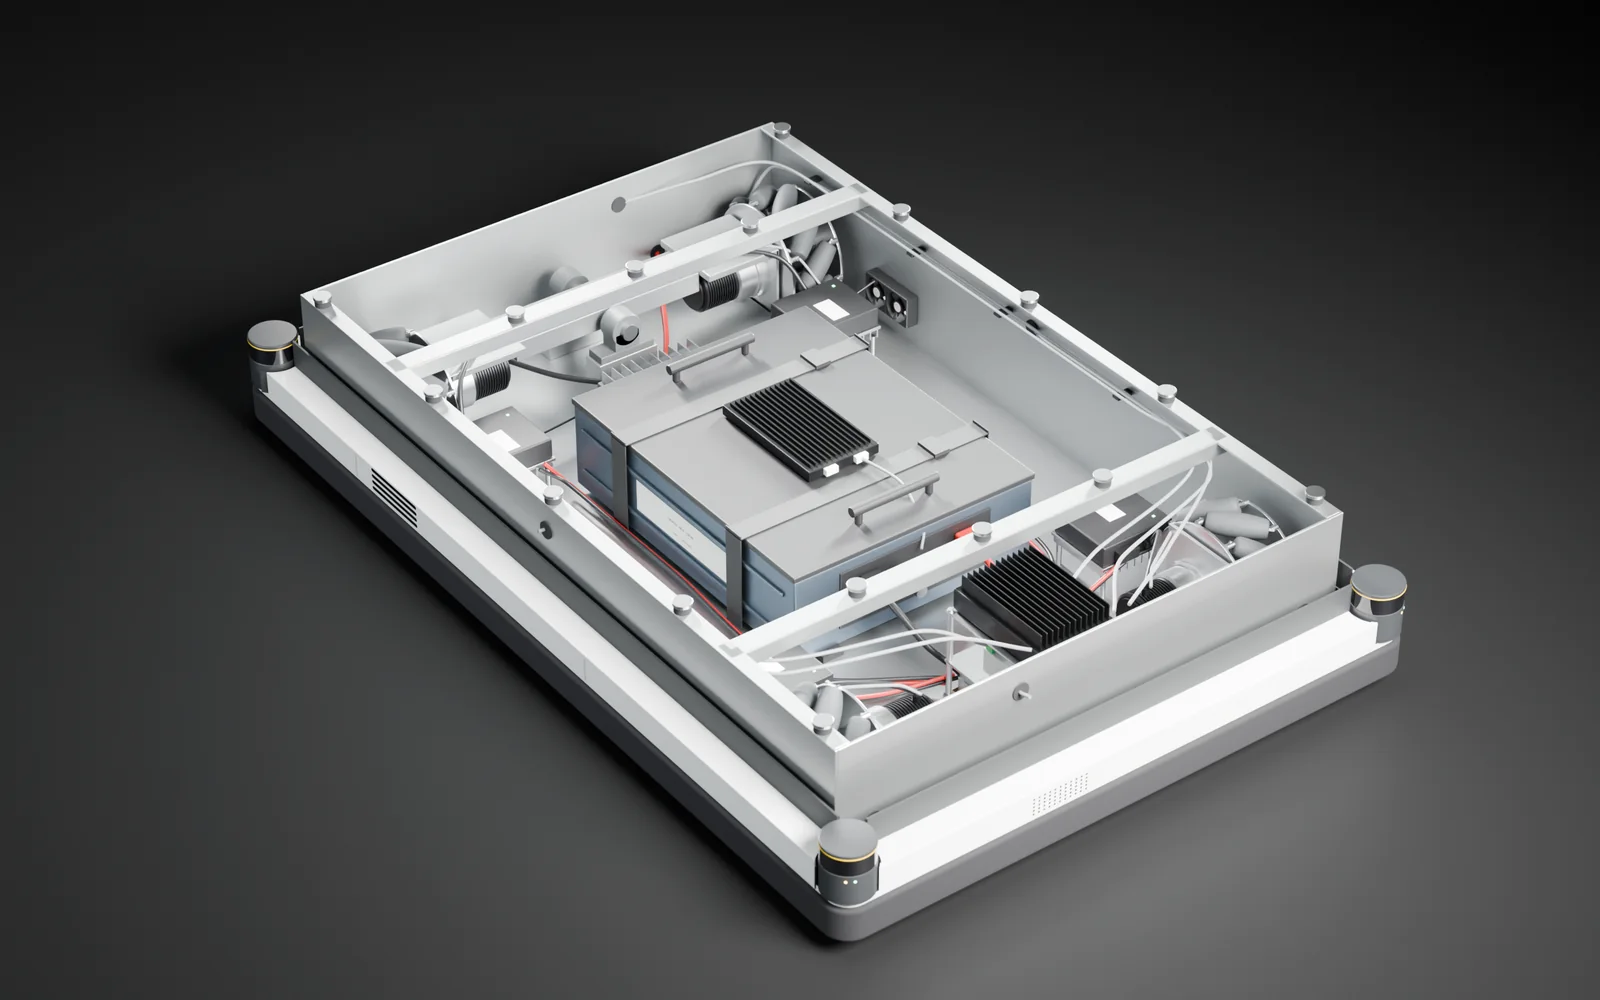
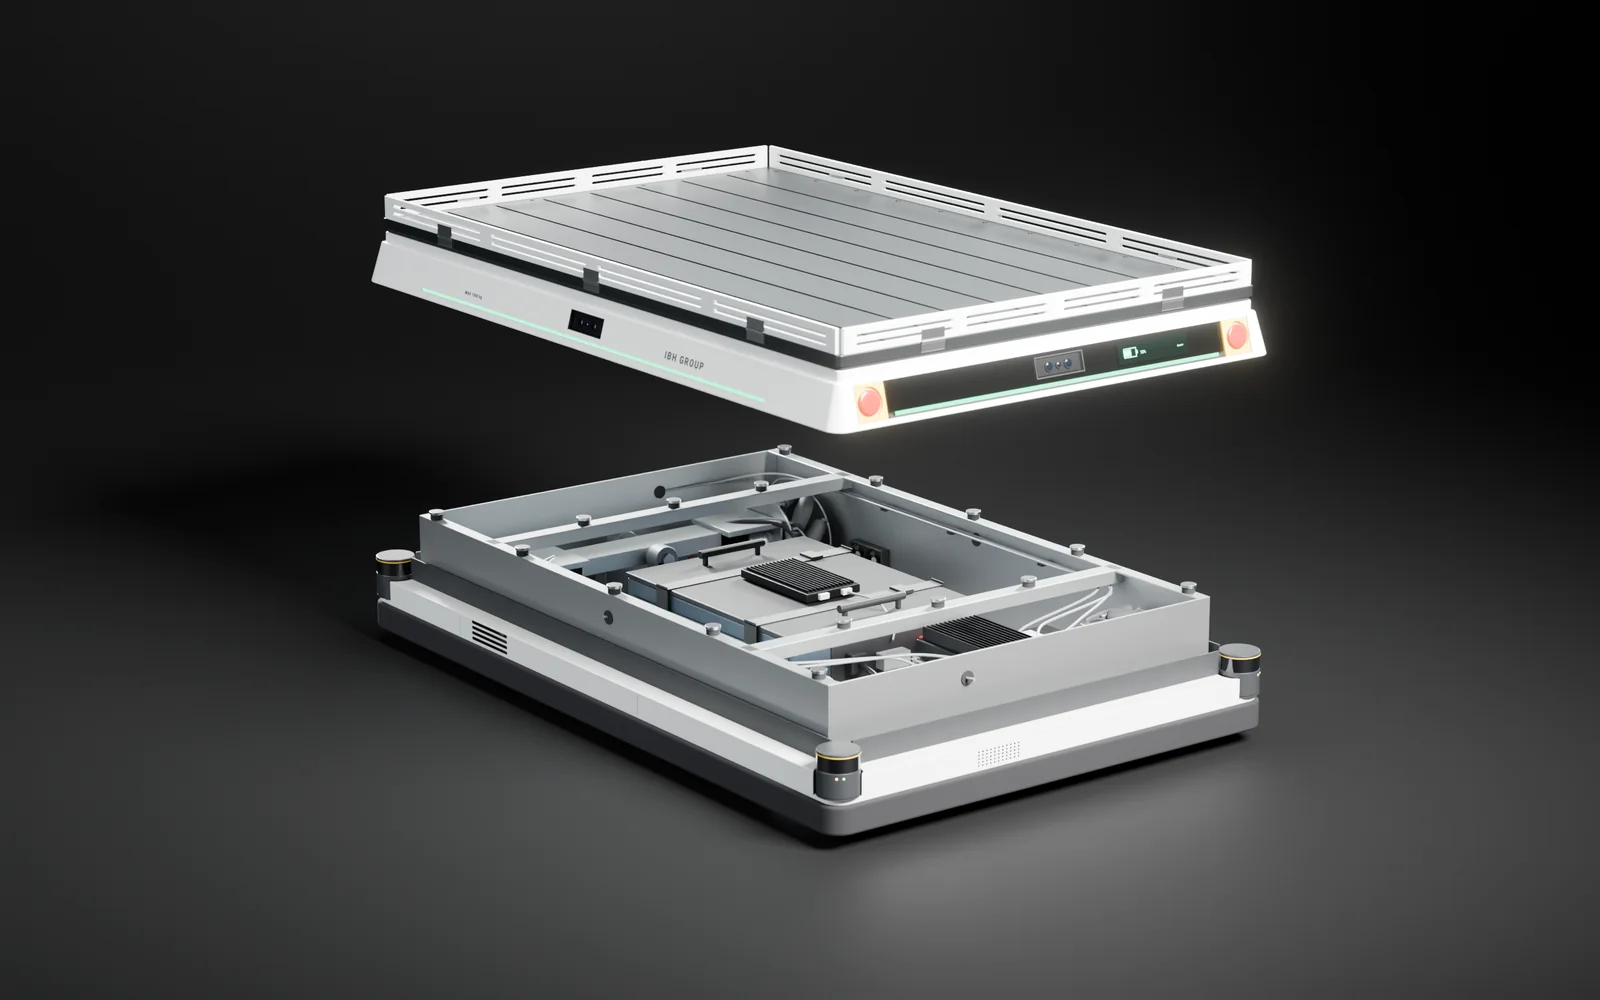
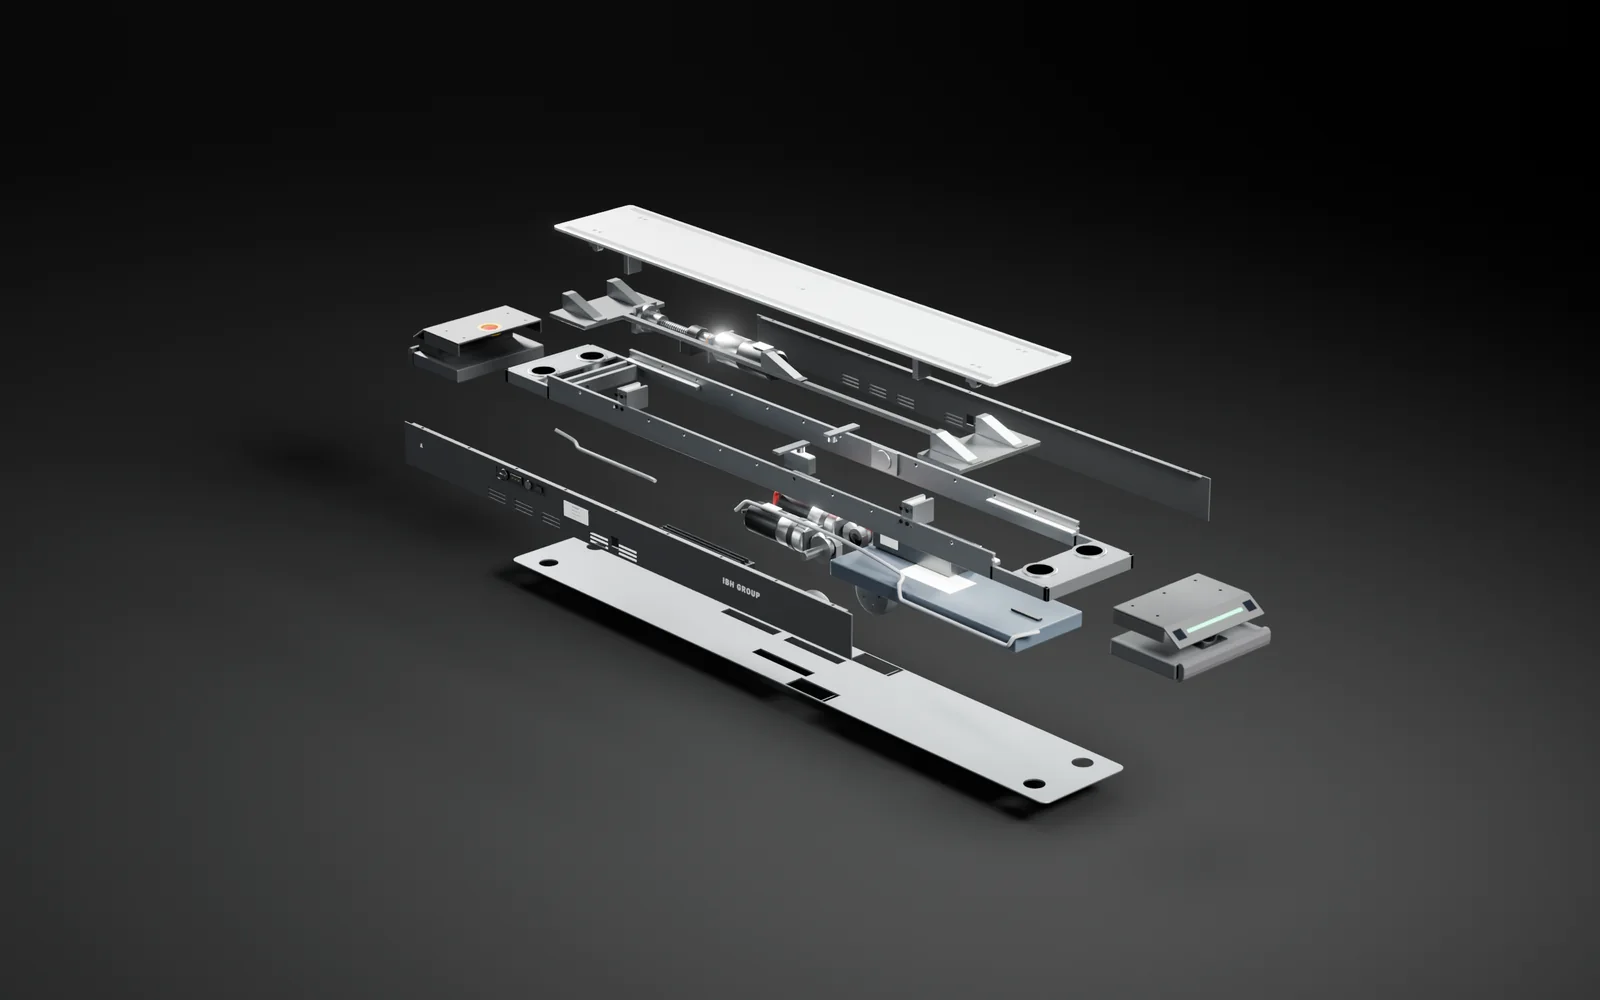
From body to components
Overview
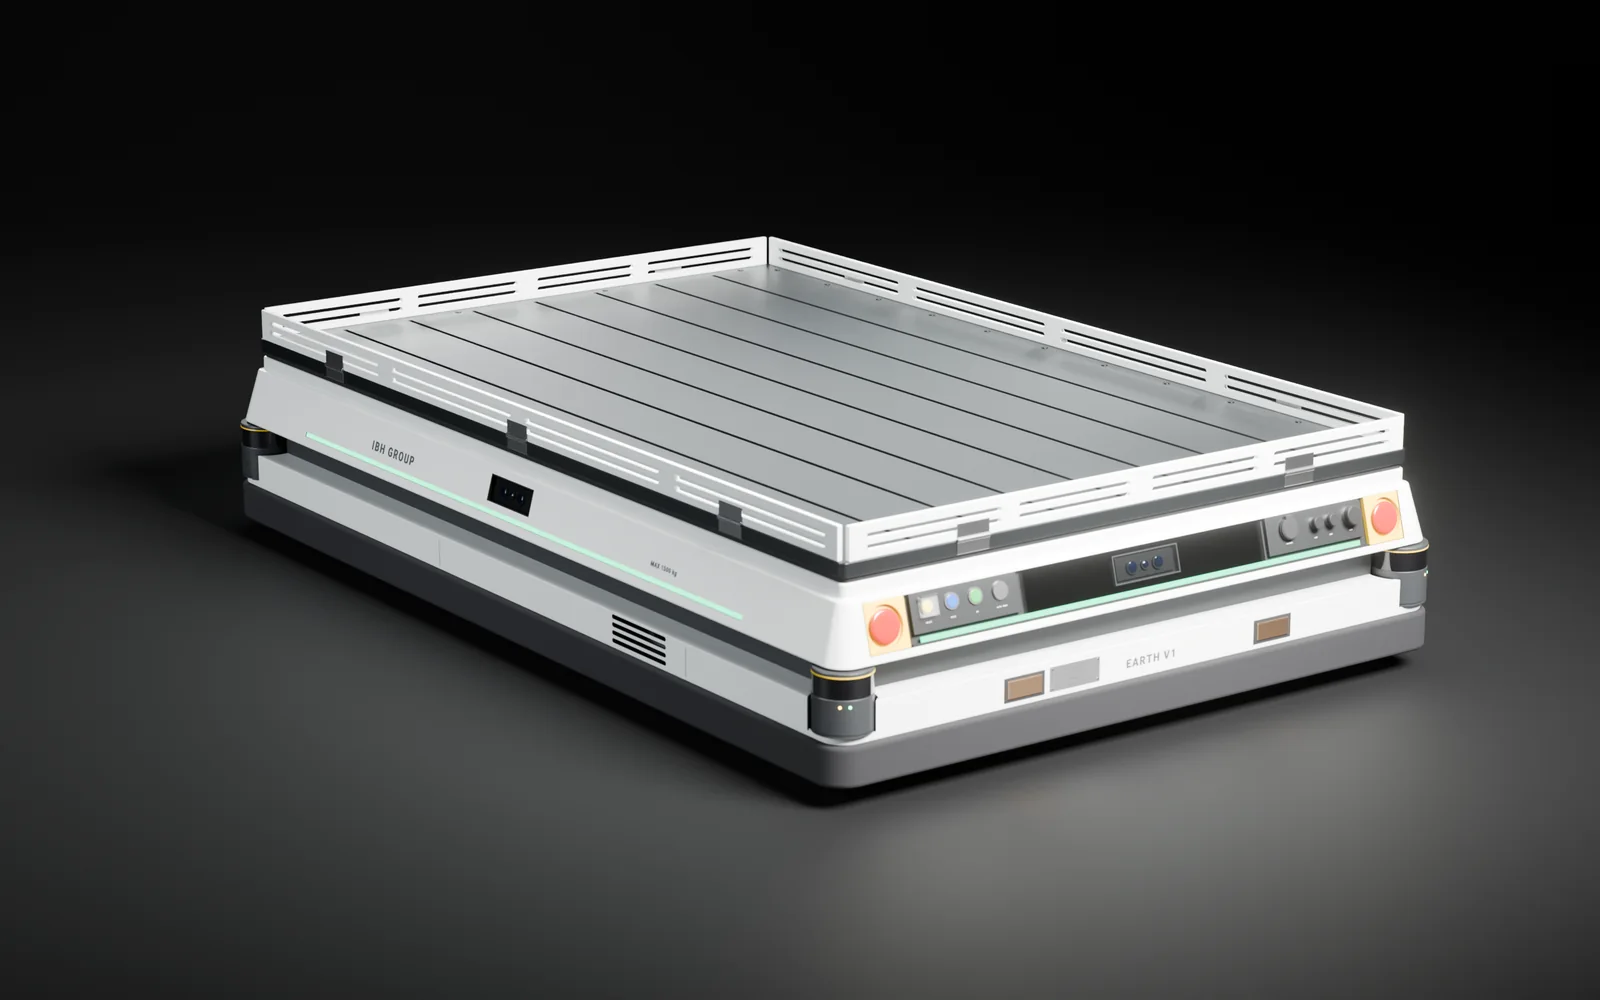
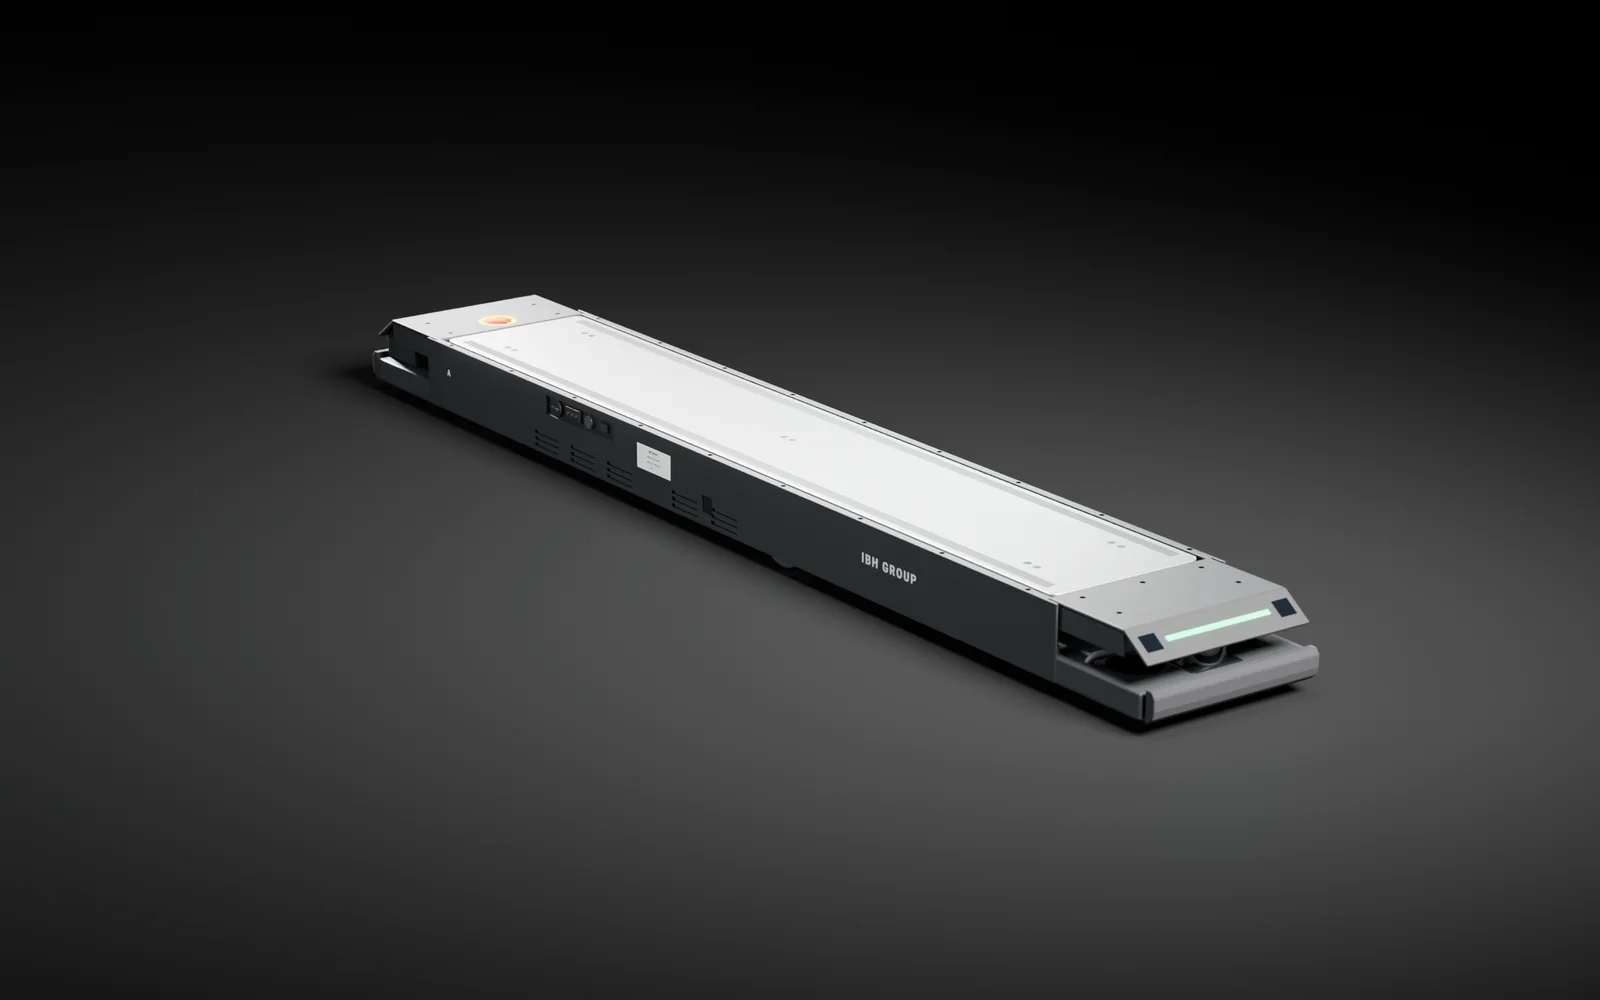
A 1640 × 1040 mm deck in anodized aluminium with seven T-slots: Euro and ISO pallets sit directly on it, and foldable, removable guard rails hold the load in place.
Inside
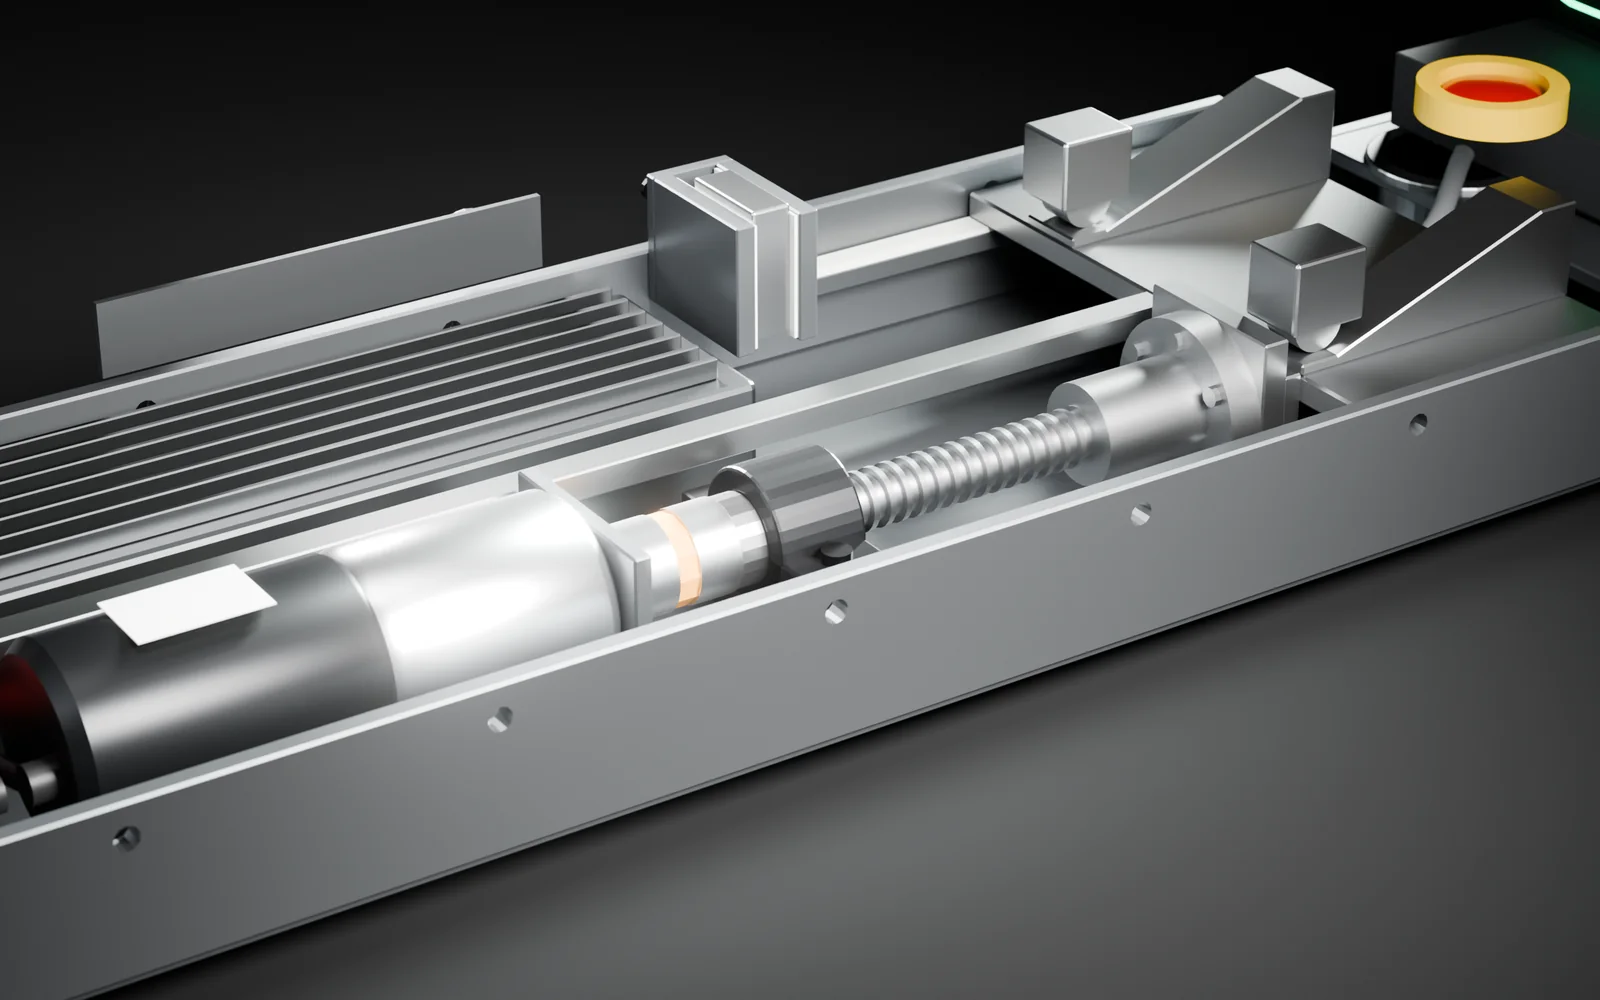
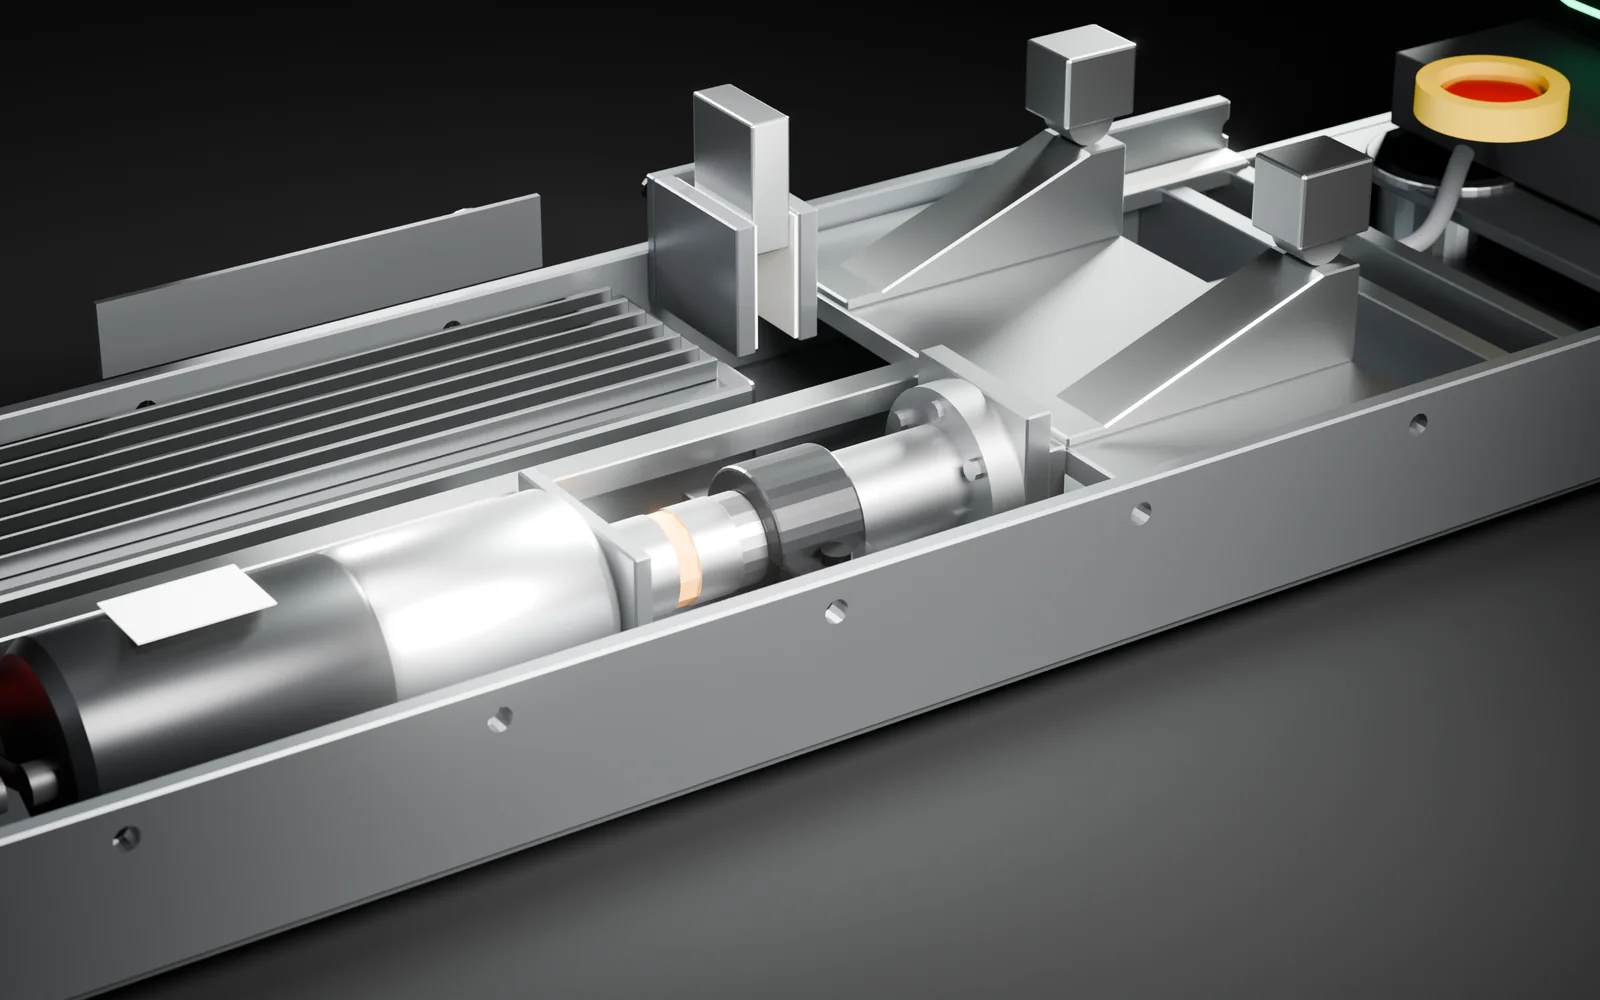
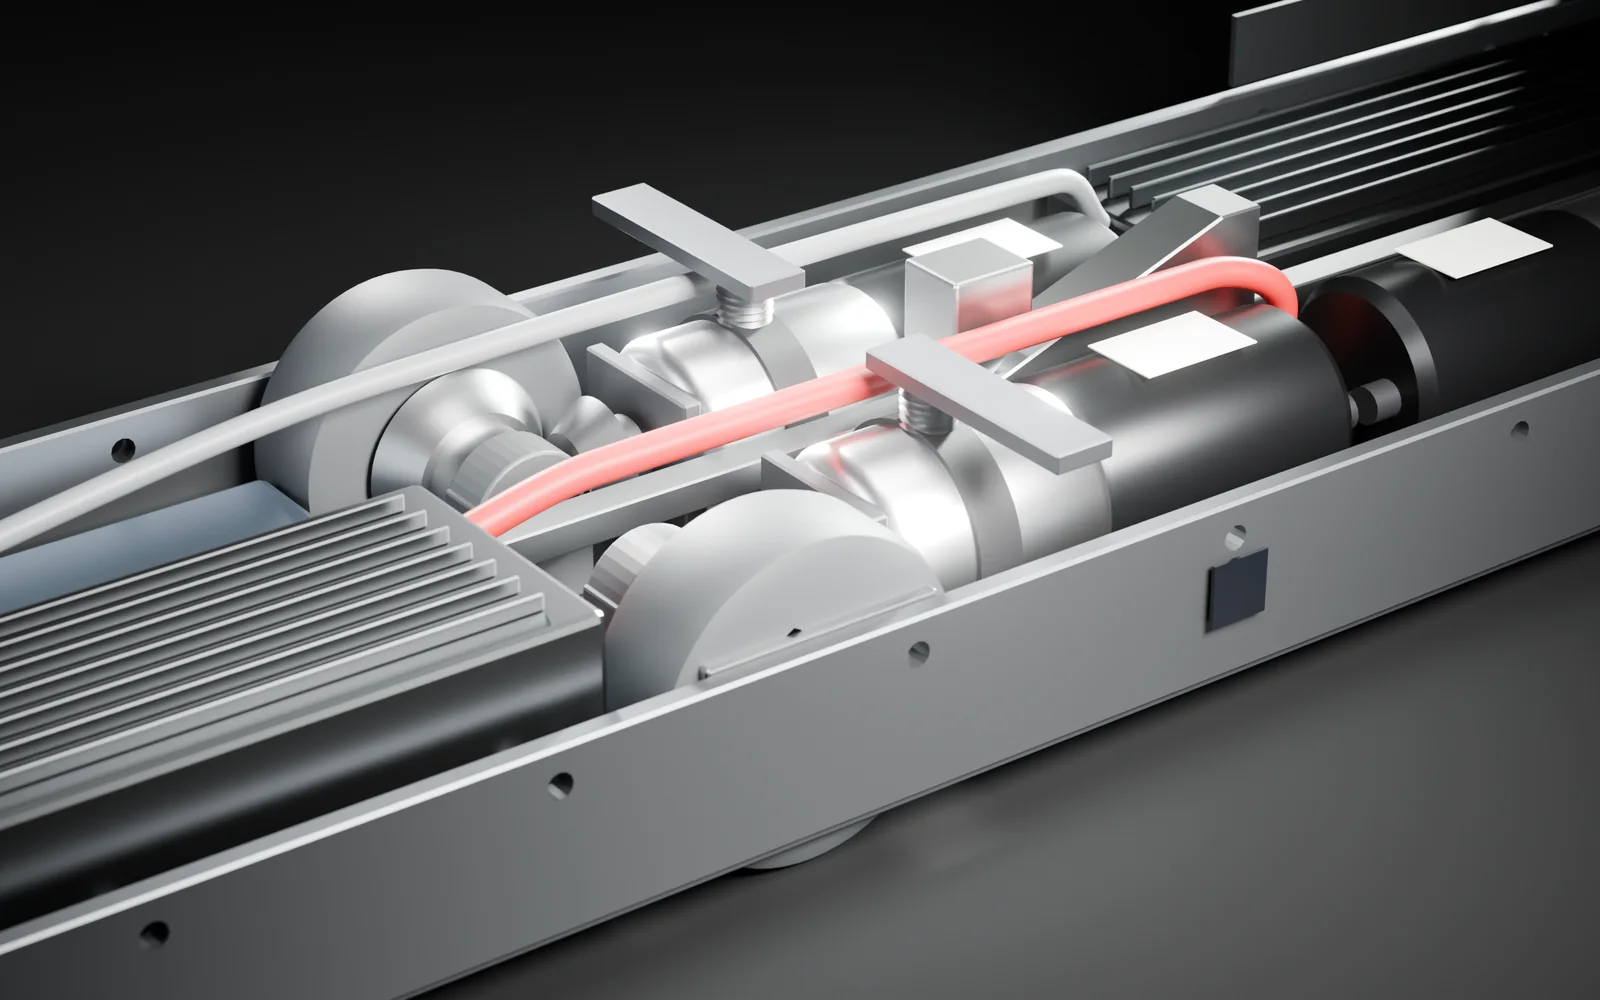
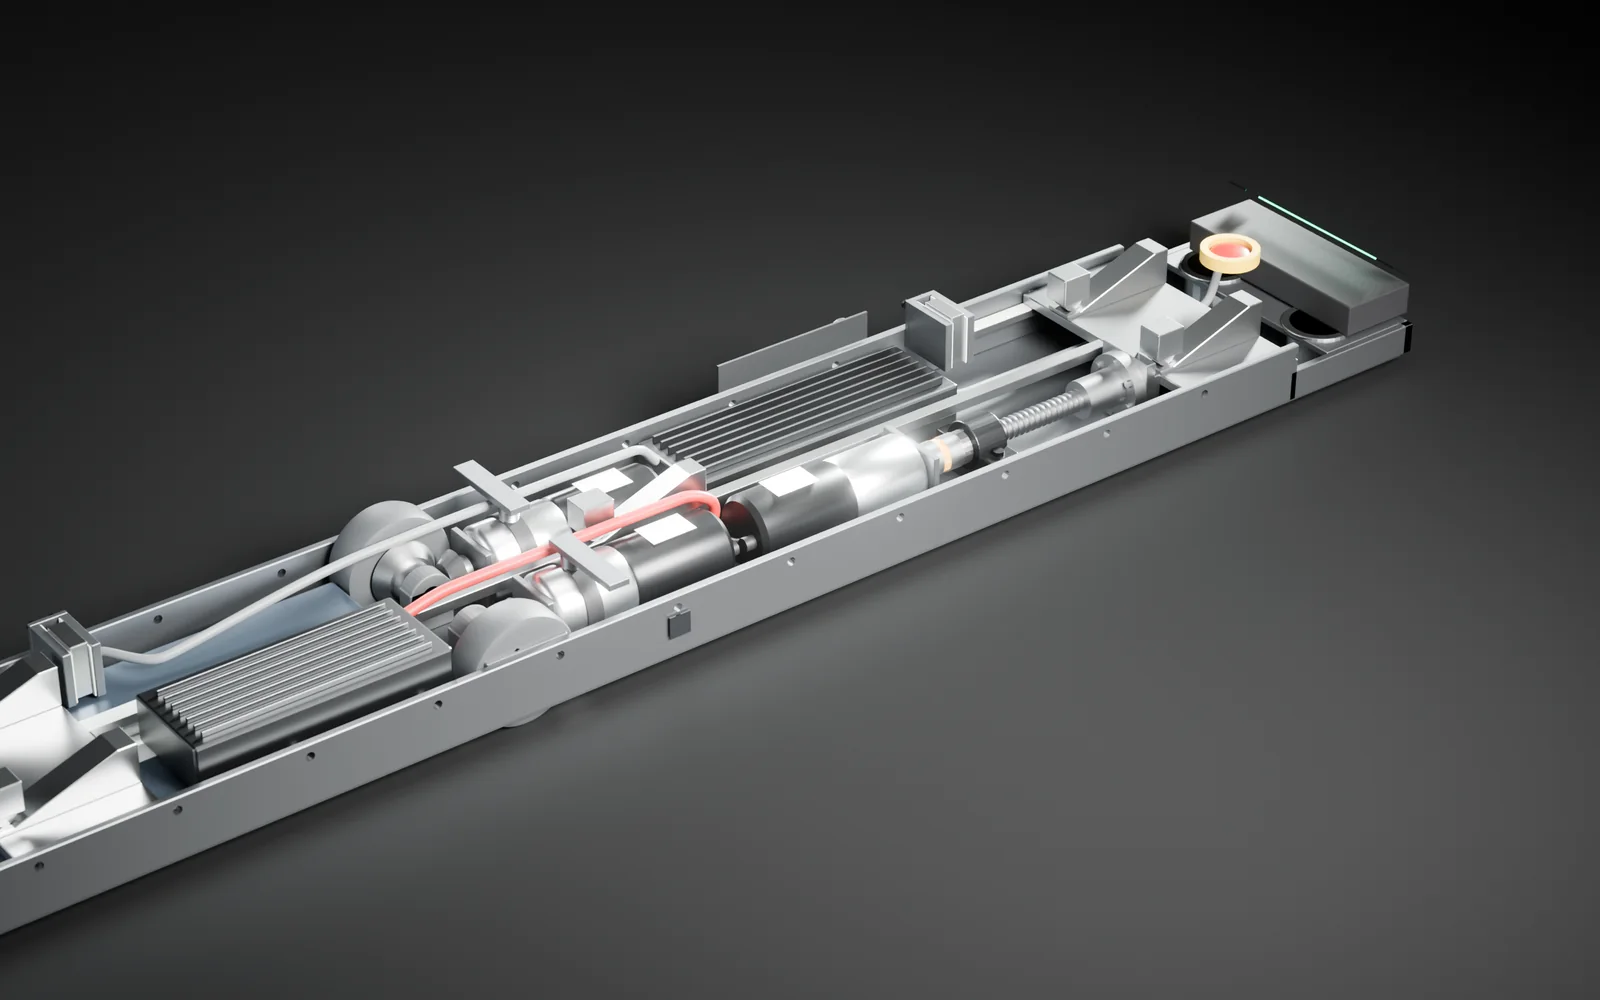
A steel tub chassis, a 7.2 kWh LiFePO4 battery, the AI computer and four geared motors; an independent safety controller watches the LiDARs, emergency stops, bumper and brakes, separately from the main computer.
Components
Under full load the chassis deflects just 0.2 mm, and the pivoting rear axle, with three degrees of swing each way, keeps all four wheels on the ground on uneven floors.
Key capabilities
Up to 1,500 kg, any load
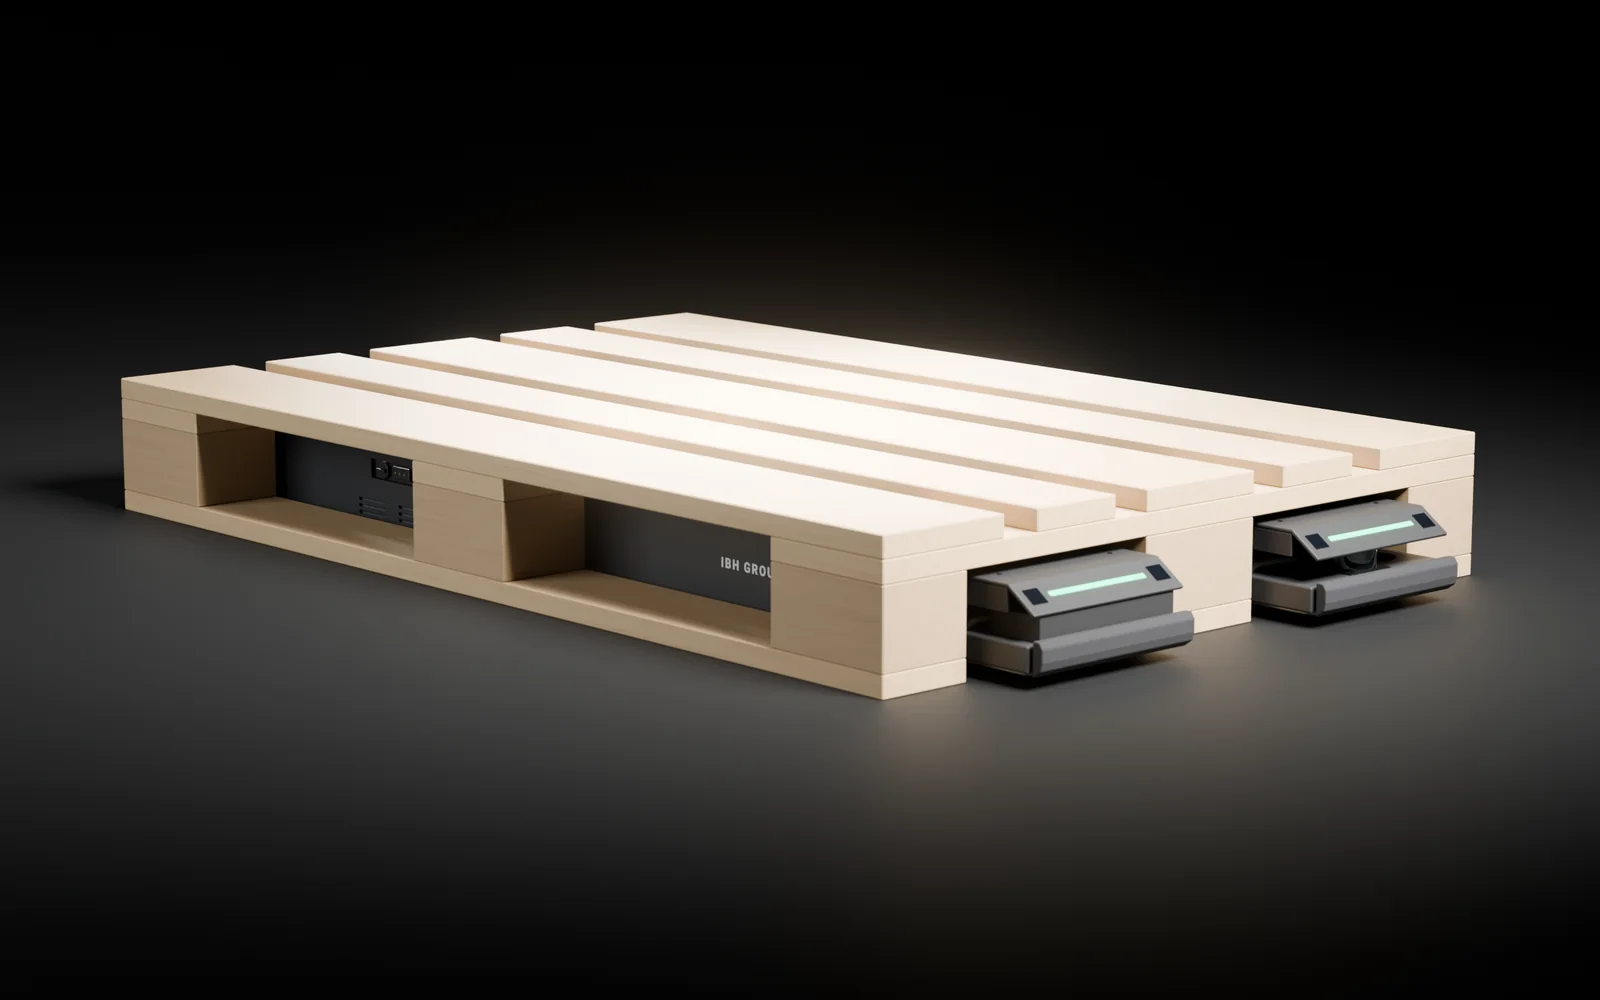
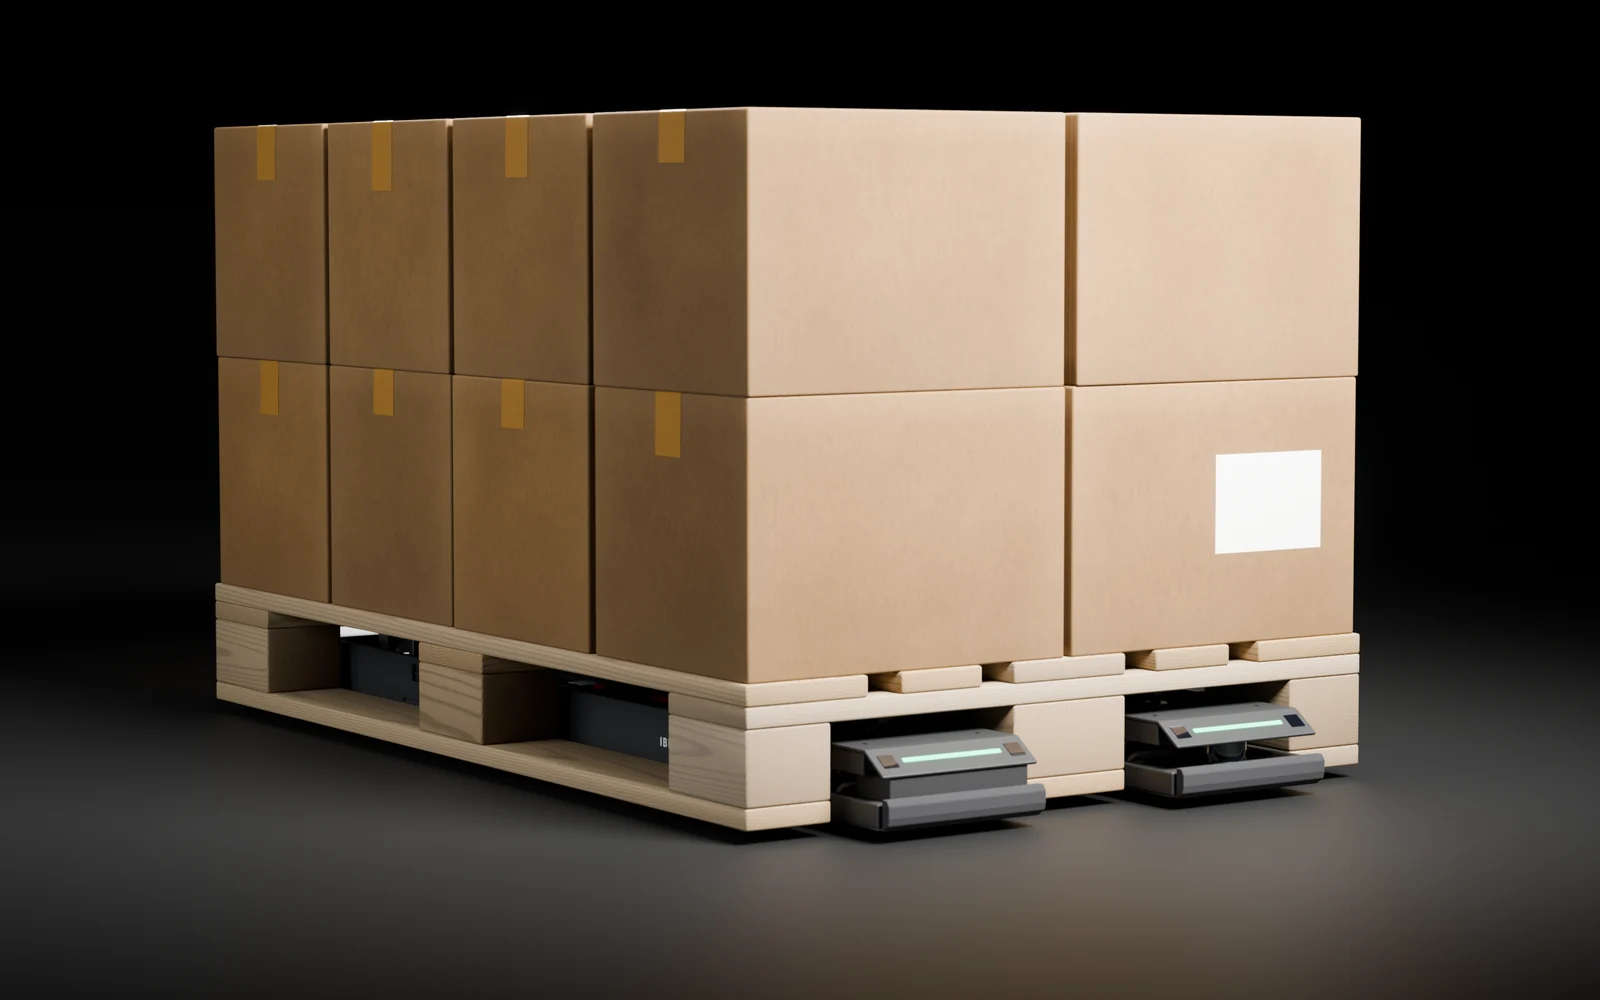
Euro (1200 × 800) and ISO (1200 × 1000) pallets sit directly on the aluminium deck, and racks, roller conveyors or lifts bolt onto its seven T-slots: one robot for pallets, racks and custom modules.
Omnidirectional motion
Four driven mecanum wheels move it sideways and diagonally without turning around and spin it in place within a circle about 2 m across. The rear axle pivots, so all four wheels stay on the ground and keep their grip on uneven floors.
360° safety
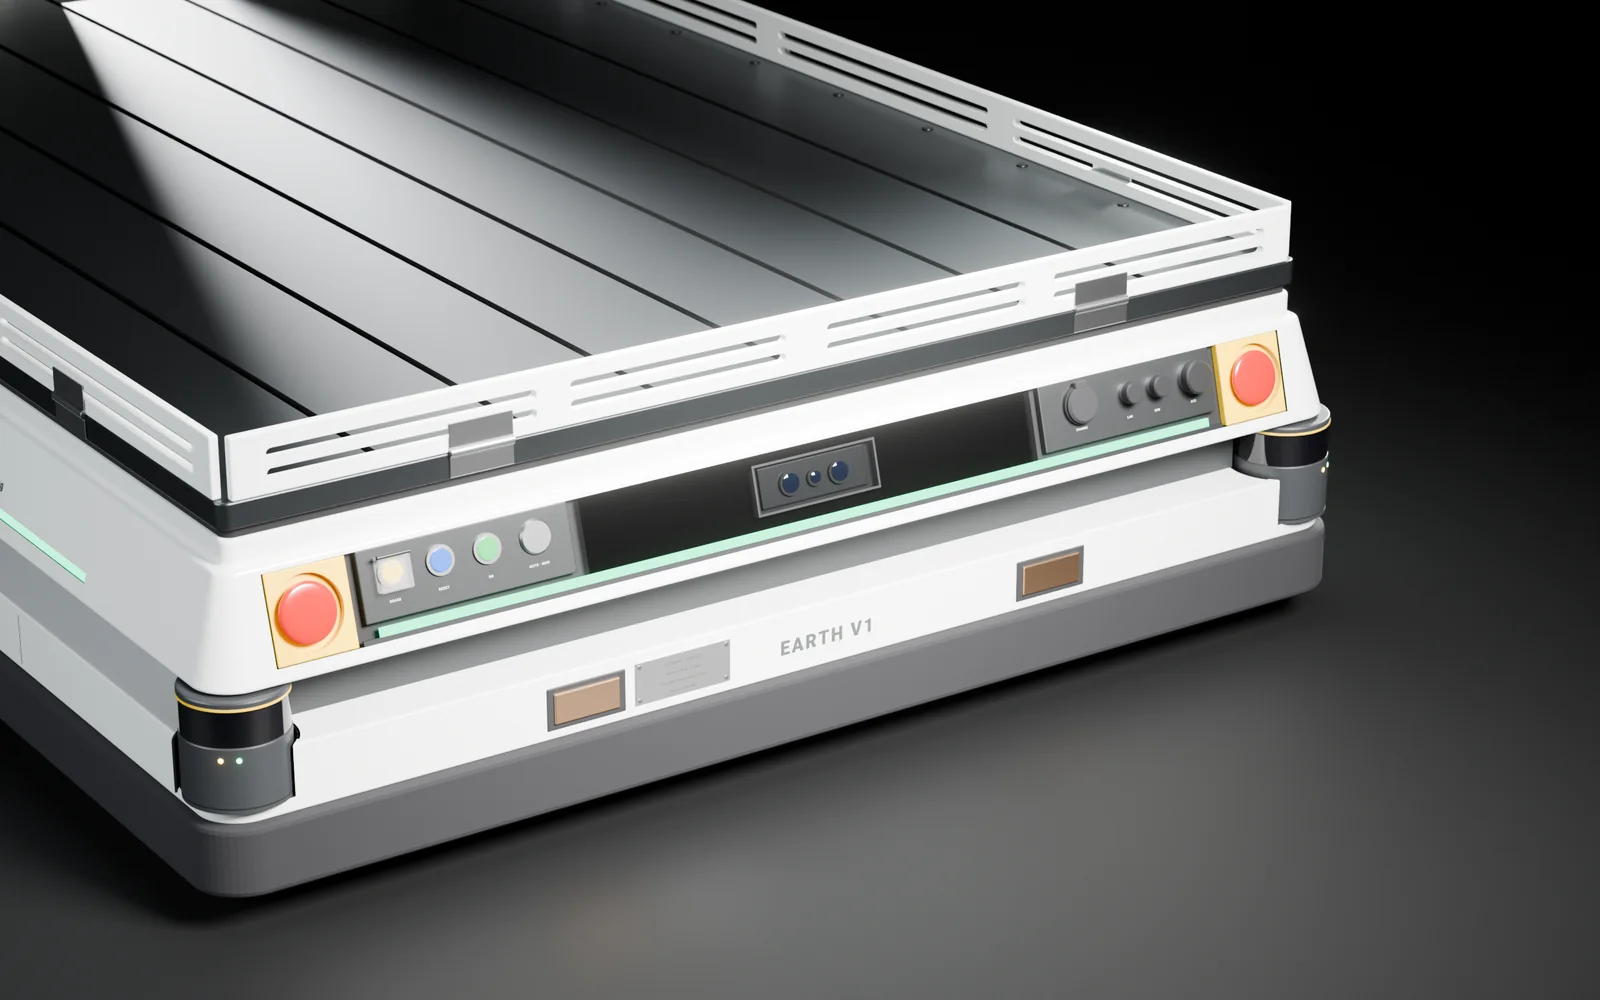
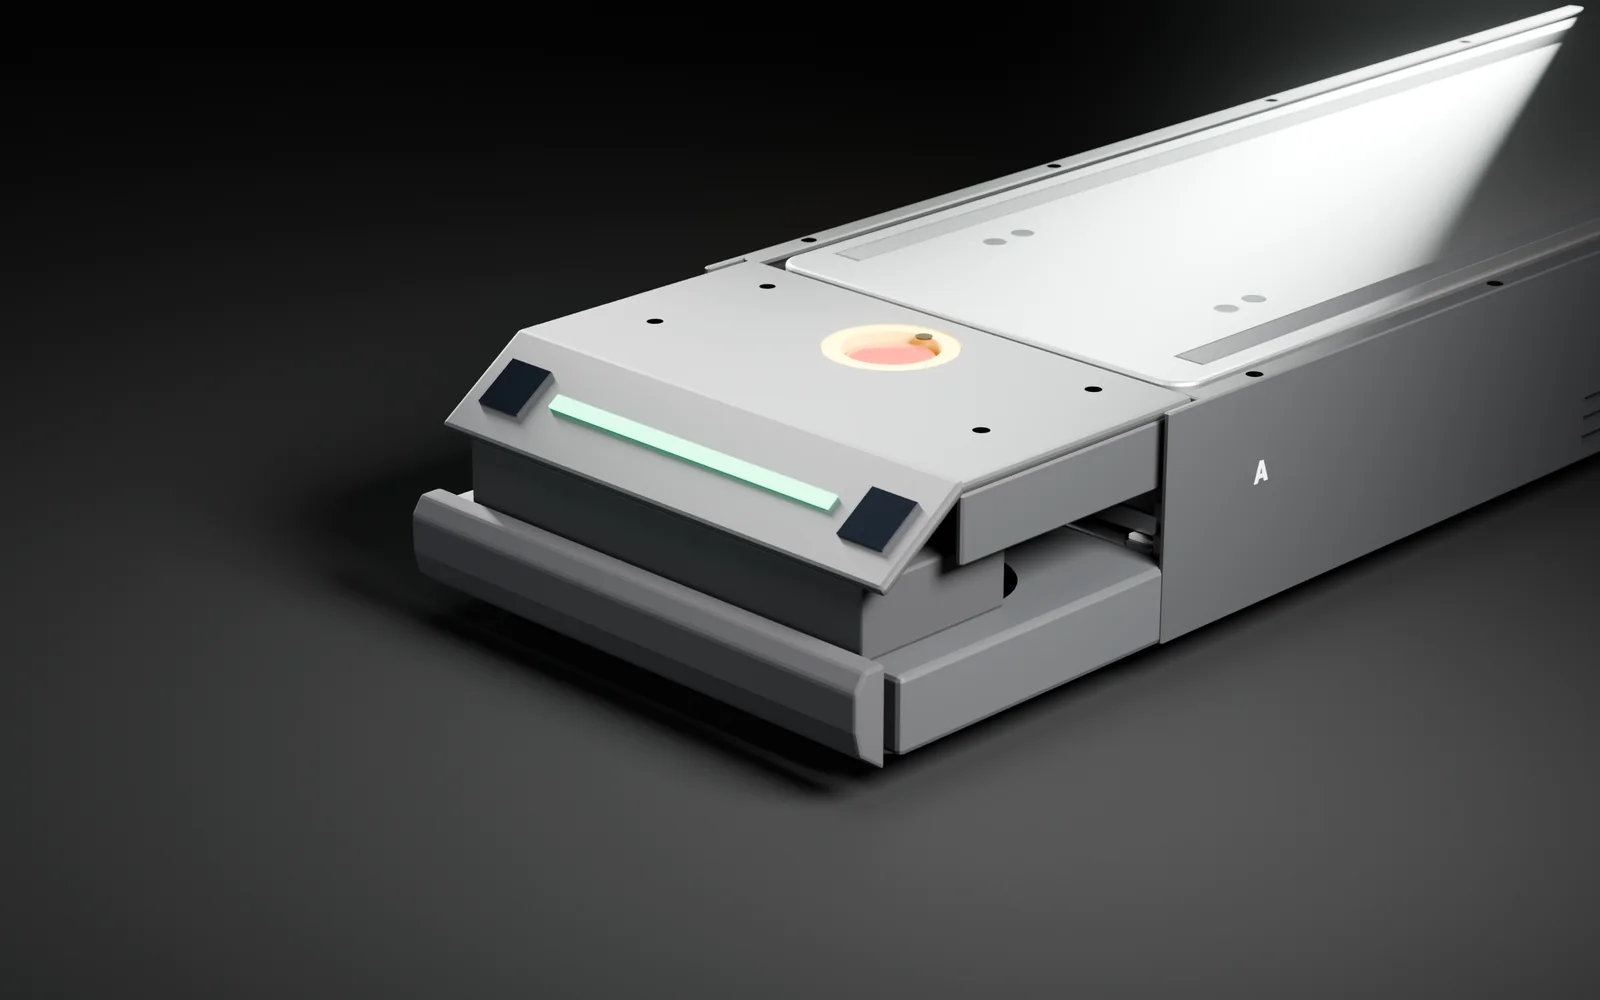
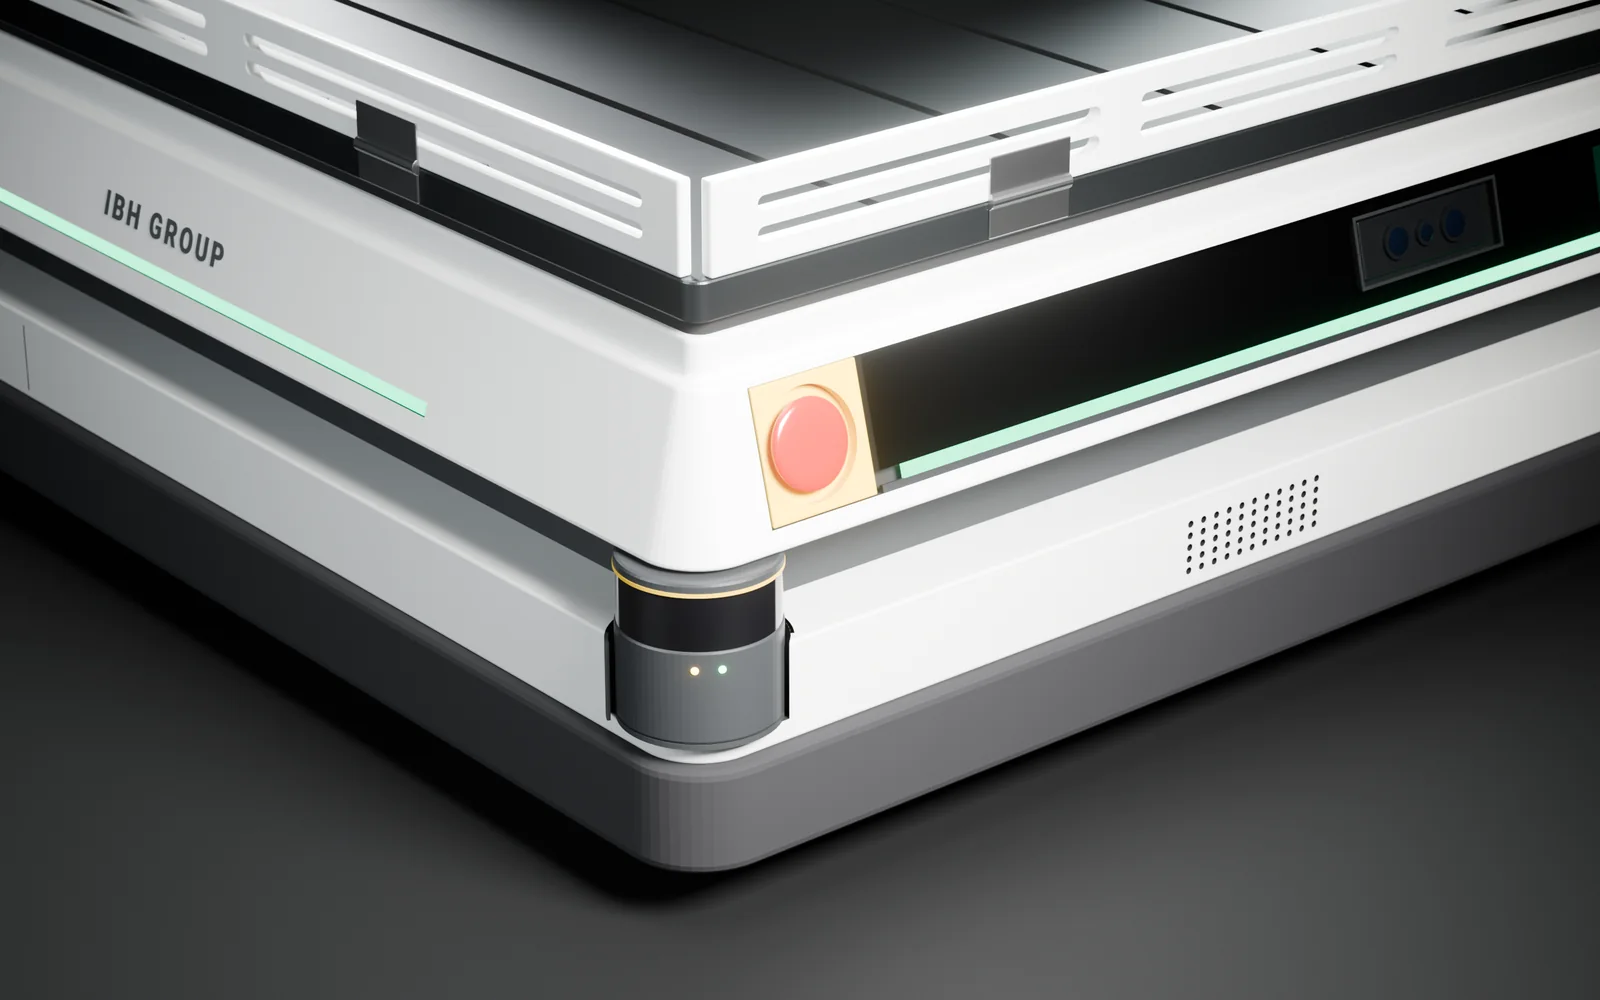
Four 270° safety LiDARs at the corners see every direction of travel with two sensors each, and four depth cameras catch obstacles above the LiDAR plane. A rubber bumper all round, four emergency stops, a status light strip and a warning speaker work through an independent safety controller.
On-board AI
The AI computer on board handles infrastructure-free navigation, human and obstacle detection and real-time path planning: decisions are made on the robot itself, with no dependence on a server.
More than one shift
The 7.2 kWh LiFePO4 battery gives about 16 hours of work, more than a full shift. The robot drives itself to its charging station and docks, and a manual charging socket is there too.
Ready to integrate
A rear panel with an auto/manual switch, safety reset and brake release for pushing by hand; two M12 ports for Ethernet and USB; and an AUX connector that powers and controls modules on the deck. The 5 cm guard rails fold down and come off.
3D view
Specifications
Figures marked “proposed” will be confirmed by the engineering team before release.
Size & capacity
- Dimensions
- 1716 × 1116 × 340 mm
- Deck
- 1640 × 1040 mm, 7 T-slots
- Payload
- 1,500 kg
- Robot weight
- about 435 kg
- Ground clearance
- 35 mm
Motion
- Drive
- 4 driven 10″ mecanum wheels
- Directions
- Forward, back, sideways, diagonal, turn in place
- Turning diameter
- 2014 mm
- Top speed
- 1.2 m/s unloaded (proposed)
Energy
- Battery
- LiFePO4, 48 V, 7.2 kWh
- Run time
- about 16 h
- Charging
- Automatic docking + manual socket
Sensing & compute
- Safety LiDAR
- 4 × 270°
- Depth cameras
- 4
- Computer
- NVIDIA Jetson AGX Orin
- Interfaces
- 2 × M12, AUX connector
Main applications

- Moving pallets and racks between storage and production
- Feeding assembly lines with heavy parts
- Station-to-station transfer in vehicle and parts manufacturing
- Warehouses with narrow aisles
- Halls where people and robots work side by side
Gallery